Xiangyu Miao 「缪翔宇」

Portrait of Xiangyu Miao 「缪翔宇」

I am a third-year master's student at Shanghai Jiao Tong University, advised by Prof. Weinan Zhang (张伟楠). I also completed my undergraduate studies at SJTU.

During the first half of my master's program, I joined an engineering exchange program at École Polytechnique in France.

My research lies at the intersection of reinforcement learning, humanoid robotics, and general-purpose loco-manipulation, with a focus on foundation policies that unify perception and whole-body control.

I aim to develop learning-based methods that enable humanoid robots to move and interact with the physical world as capable whole-body agents. I believe progress in embodied intelligence will come from combining effective algorithmic structure with diverse, scalable experience, so that learned policies can generalize across behaviors, environments, and embodiments.

CV coming soon

WeChat

WeChat QR code for Xiangyu Miao
Google Scholar ORCID

Selected work

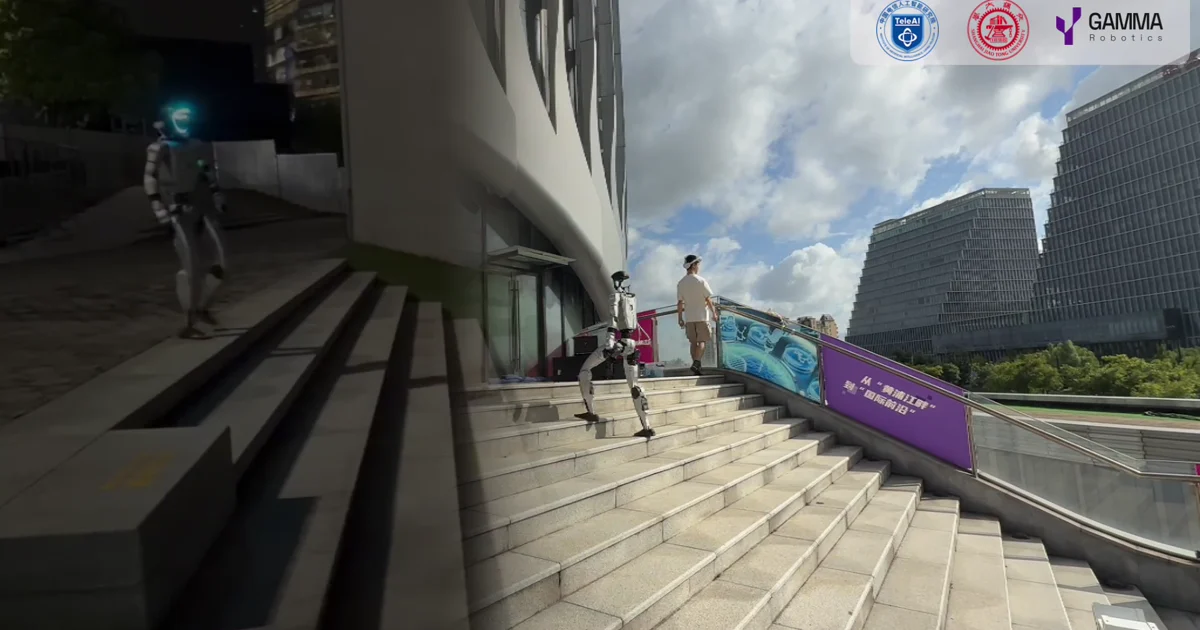
NEXUS terrain-adaptive humanoid whole-body teleoperation

arXiv 2026 · Preprint

NEXUS: Perceptive Whole-Body Control for Terrain-Adaptive Teleoperation

Xiangyu Miao, Junsong Wu, Jiyuan Shi, Weiji Xie, Jinrui Han, Xingyi Wang, Weinan Zhang, Chenjia Bai, and Xuelong Li

Perceptive whole-body control for humanoid teleoperation across mismatched human and robot terrains, trained on nearly 1,000 hours of paired motion data and deployed zero-shot on unseen real-world terrains.
Publications

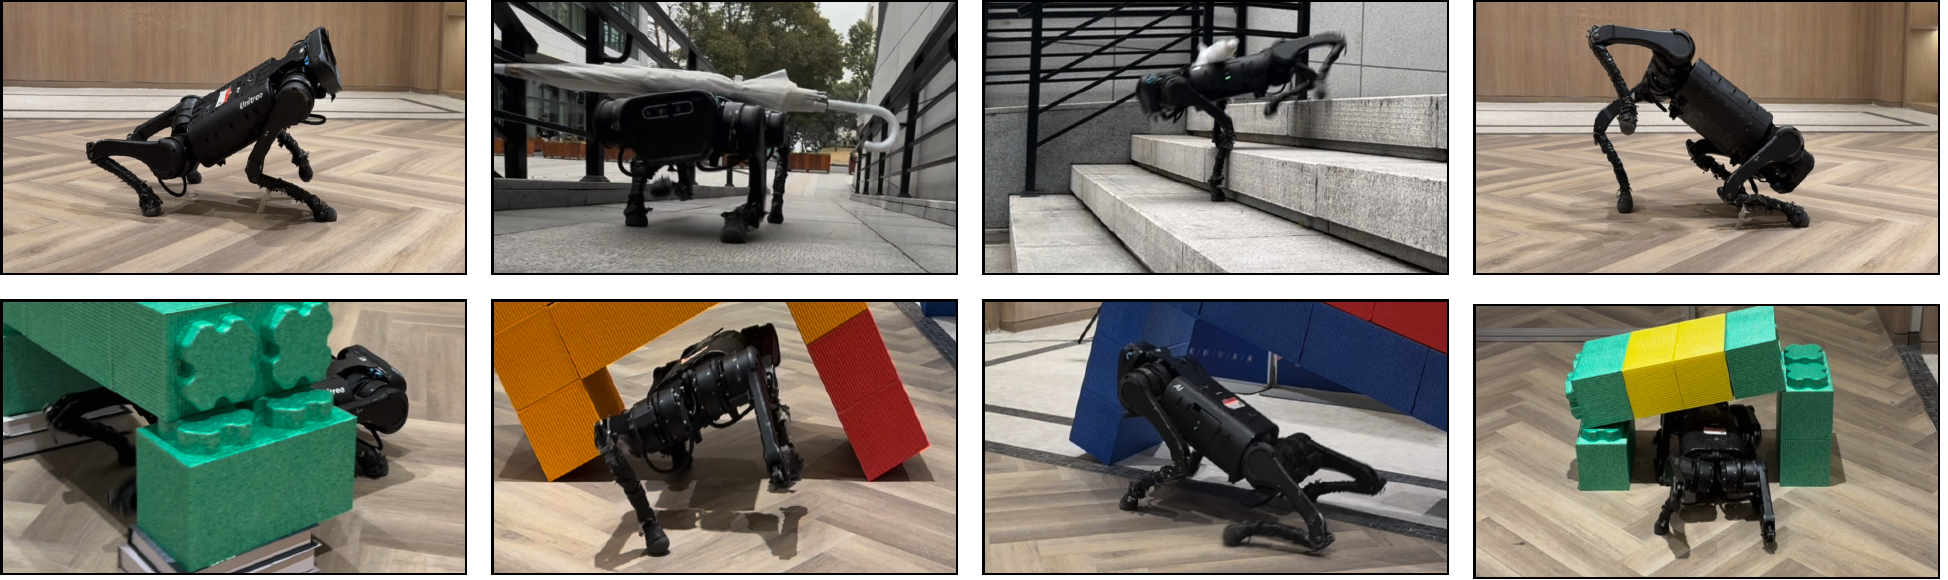
Unitree A1 quadruped robot demonstrating posture-aware locomotion across diverse real-world terrains

DAI 2025 · Oral · Conference paper

Learning Embodied Quadruped Agents for Posture-Aware Locomotion

Xiangyu Miao, Jun Sun, Hang Lai, Xinpeng Di, Jiahang Cao, Yong Yu, and Weinan Zhang

An end-to-end reinforcement learning framework for quadruped locomotion that jointly tracks velocity commands and regulates body posture, with sim-to-real transfer to real-world robots.

Career & Education History